Japan's METI-backed AIRoA releases AIRoA-0 robot model trained on human recordings
The vision-language-action model learns from 16,000-plus hours of people using a handheld gripper rather than from robot teleoperation.
 Takehiko Ohkawa et al. (AIRoA) · CC BY-SA 4.0
できること
- Training data
- 16,151 hours of handheld human demonstrations
- Average success, 10 two-arm tasks (AIRoA's own test)
- 78% (vs 27% for best rival)
The AI Robot Association (AIRoA), a Tokyo body backed by Japan's Ministry of Economy, Trade and Industry, has released AIRoA-0, a vision-language-action model that links language and vision to robot control. AIRoA lists the release date as 6 November 2026.
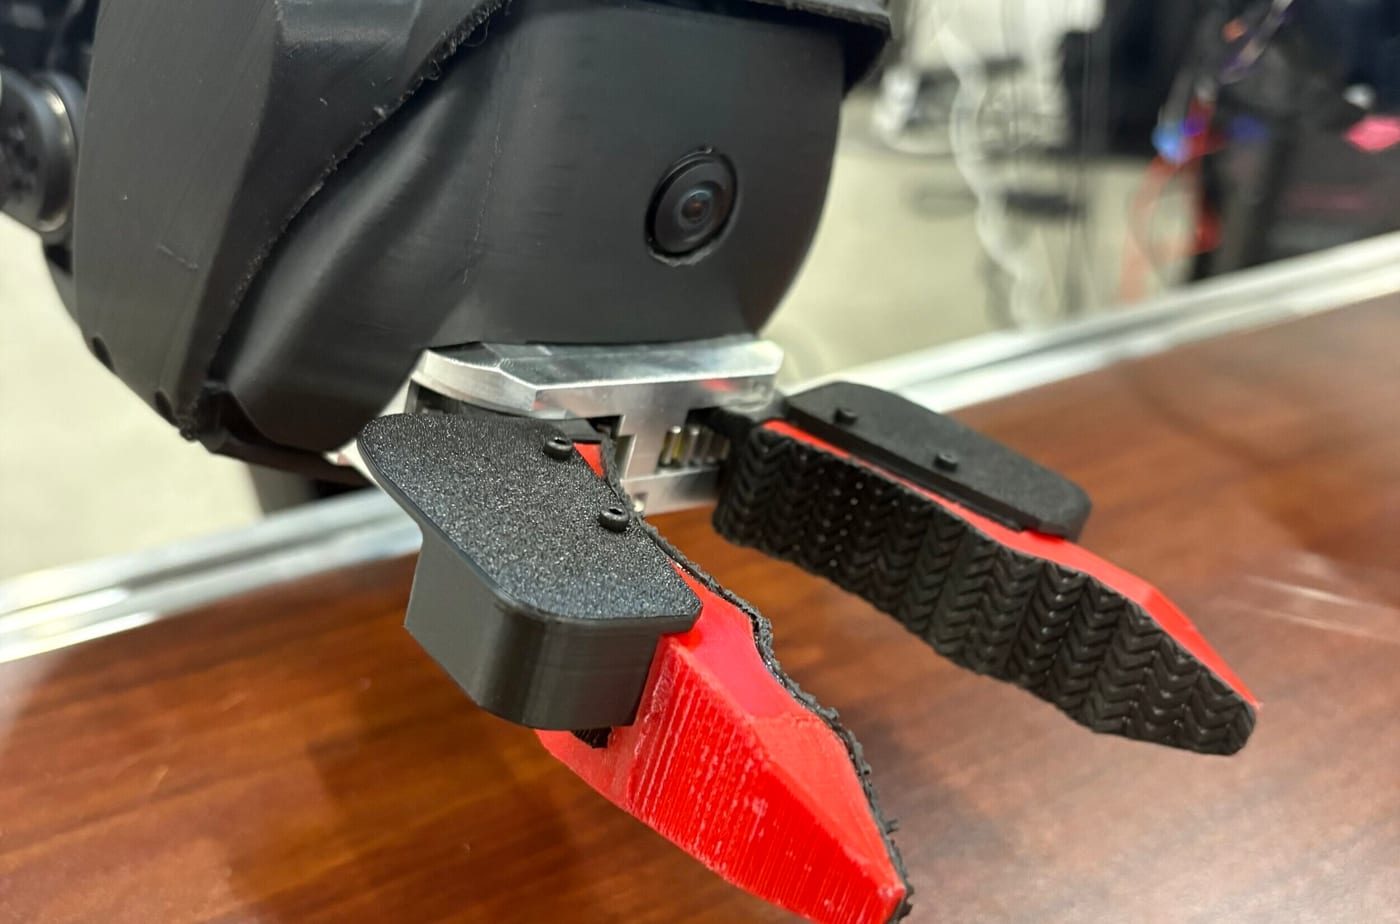
Its training data came from more than 16,000 hours of everyday tasks recorded with YUBI, a handheld gripper developed with Toyota, instead of demonstrations driven through a robot. It is built on Physical Intelligence's open π0.5 model. Weights are on Hugging Face under Gemma terms and the code is Apache-2.0; the training data itself has not yet been released.
Collecting data with handheld tools instead of robots is cheaper and faster, which matters for Japan's effort to build a shared data base for domestic robot makers. AIRoA reports a 78% average success rate across ten two-arm tasks, against 27% for the best of four rival models trained on the same data; no independent benchmarks are available yet.
この記事は上記の出典をもとにAIが下書きし、公開前に9DOFの編集者が確認しました。数値は出典の報道どおりです。誤りを見つけたら お知らせください 。このページで訂正します。